Hi, I'm Aarav, an undergrad at IIT Bombay. I am passionate about using artificial intelligence to solve real world problems in robotics and medicine. My current research goal is on JEPA based World Models for Hierarchical Planning. I am also working on building multi-omic foundational models that can be used to predict disease progression and design patient-specific drugs.
Ongoing Research
Efficient Planners for World Models
Building a novel MPC based planner for vision-based world models, for efficient exploration of trajectories in latent space for goal-image conditioned tasks.
Supervised by Amir Bar, META (FAIR)
Hierarchical JEPA for long-horizon planning
Following LeCun's position paper to add a Systems-2 JEPA on top of existing WMs, to perform long-horizon tasks. Also design a scalable training method, for H-JEPA.
Personal Project
Self-Supervised Multi-omic Foundation Models
Building a multi-omic foundation model capable of taking any combination of gene expression, dna methylation, and other omics data, that can be used to predict disease progression, design patient-specific drugs and other downstream tasks.
Done as part of a larger project on Genotype-Induced Drug Discovery
Selected Projects
Automation Ecosystem for High-Mix Low Volume SMEs, enabling them to quickly and efficiently collect teleoperation data and use it to fine-tune generalist robots for specific tasks.
A self-balancing wheeled bipedal robot running an LQR-based control loop on a Raspberry Pi Pico, with a 9-DoF IMU for state estimation.
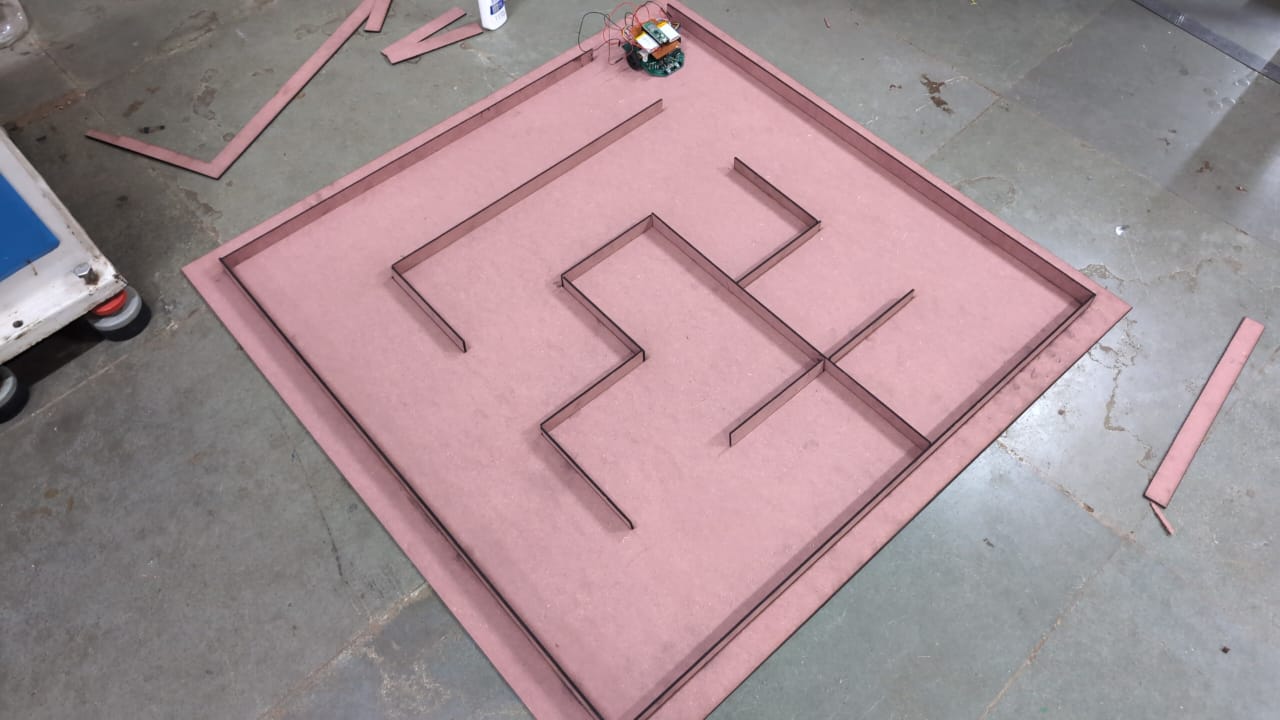
A compact, sensor-driven 2-wheeled robot build on a custom-designed PCB that autonomously navigates and quickly solves mazes.
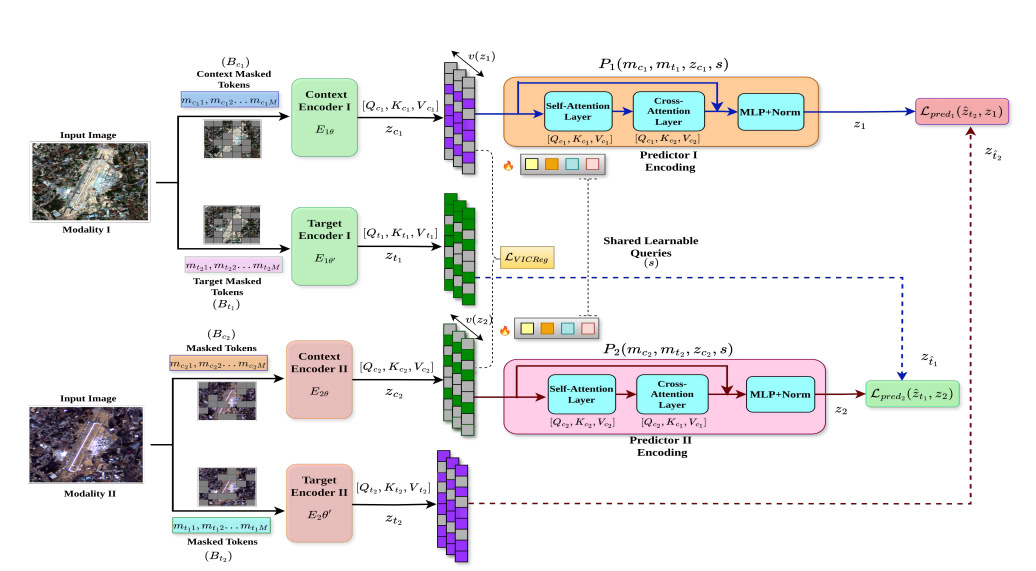
A JEPA-based cross-modal architecture, capable of taking any number of input modalities, that beats SOTA on satellite image-retrieval tasks. Paper under review.